Single Motor Failure Recovery
A quadcopter loses a rotor. It still lands.
A real-time PX4 controller that detects single-motor failure mid-flight, holds attitude on the three remaining rotors, and lands. 7th overall across all IITs.
What it does
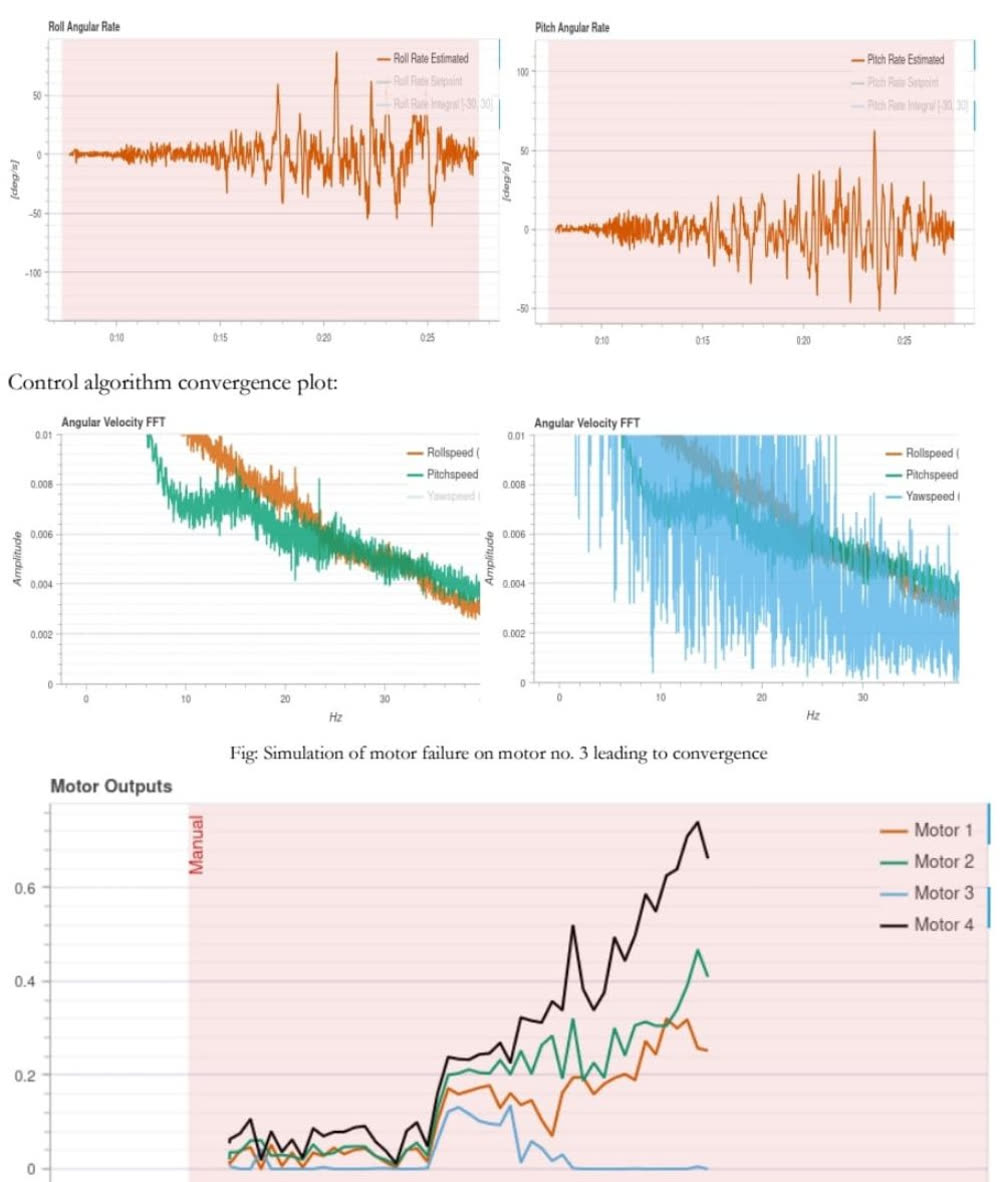
Failure detection from commanded-versus-observed body-rate mismatch, windowed against false positives
Control reallocation across three rotors with deliberate yaw sacrifice
Emergency attitude recovery and controlled descent to landing
Modified PX4 firmware, validated end to end in Gazebo
On camera
The long version
A quadcopter that loses one motor stops being a quadcopter. It becomes an underactuated vehicle that physically cannot hold yaw, and every control law written for four rotors starts fighting a problem it cannot solve.
The recovery strategy accepts that constraint instead of resisting it. Yaw authority is given up deliberately, the airframe is allowed to spin about its vertical axis, and the three surviving rotors are re-allocated to hold attitude and descent rate — enough to bring the vehicle down intact rather than invert it.
Detection is the part that has to be both fast and quiet. The controller compares commanded motor output against observed body-rate response and only declares a failure once the mismatch persists across a window, which keeps propeller wash and gusts from triggering a false recovery. The full loop was built against PX4 Autopilot and validated in Gazebo.