Physical AI · IIT Patna · open to research & internships
JayinakshaVyas
Policies · VLAs · world models — on real robots
The reel
Thirty-eight seconds across every project, cut from the real test and match footage.
Project sites
Hover a tile to play its footage.
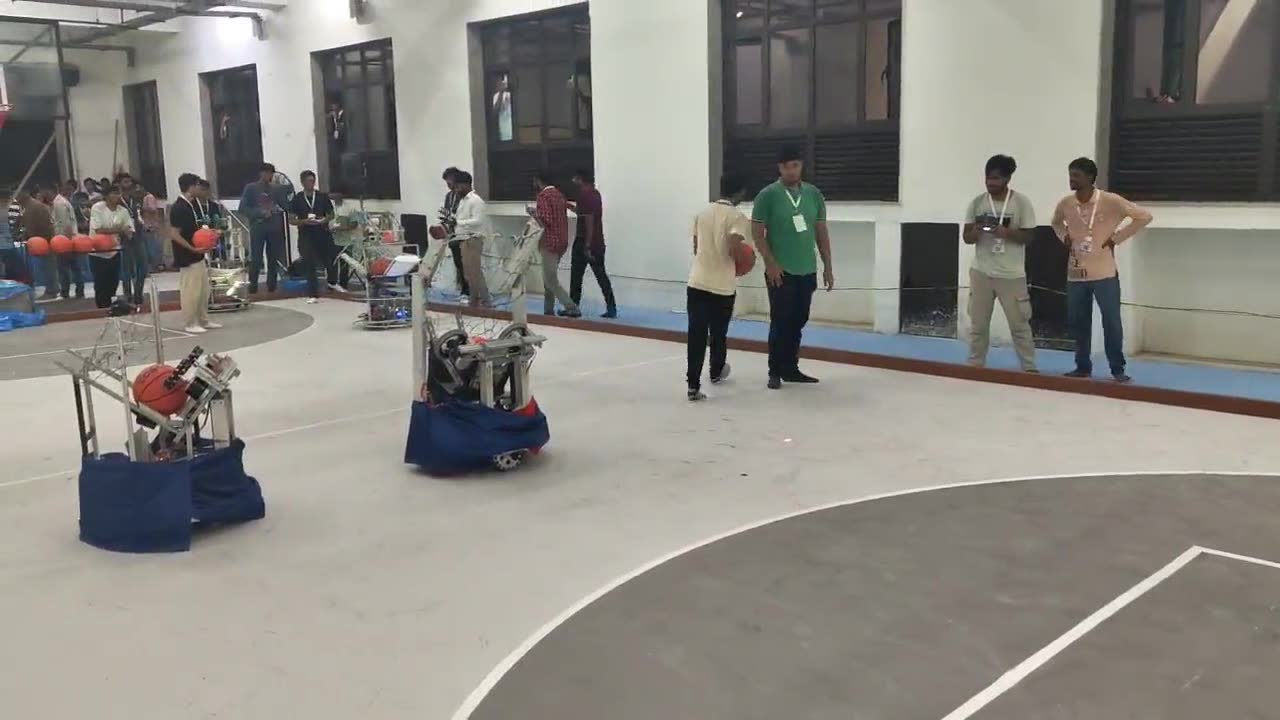 /Robocon-25_codes
Team Phoenix
Two basketball robots — one teleoperated, one autonomous — forty engineers, one fixed deadline.
ROS 2 · ESP32 · RealSense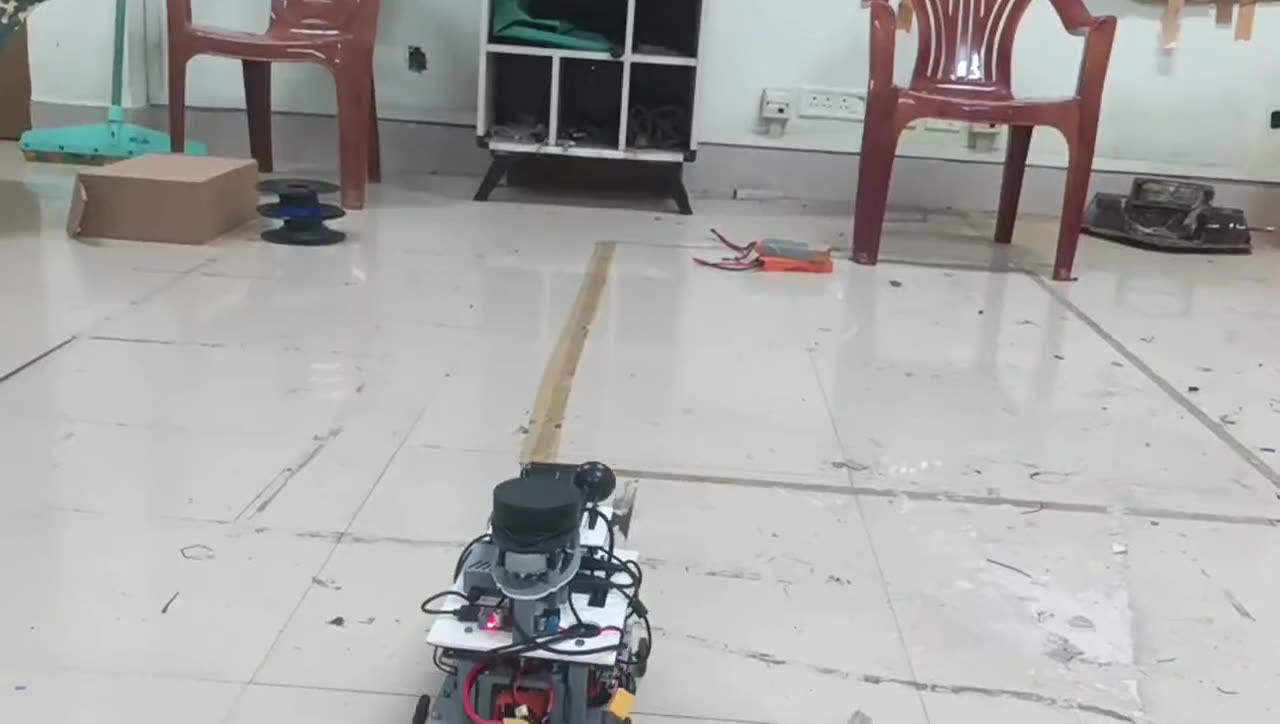 /agentic-bot
R2-D2 Redux
Say “go to the table.” A VLM, a semantic map and a 20B planner turn it into a Nav2 goal.
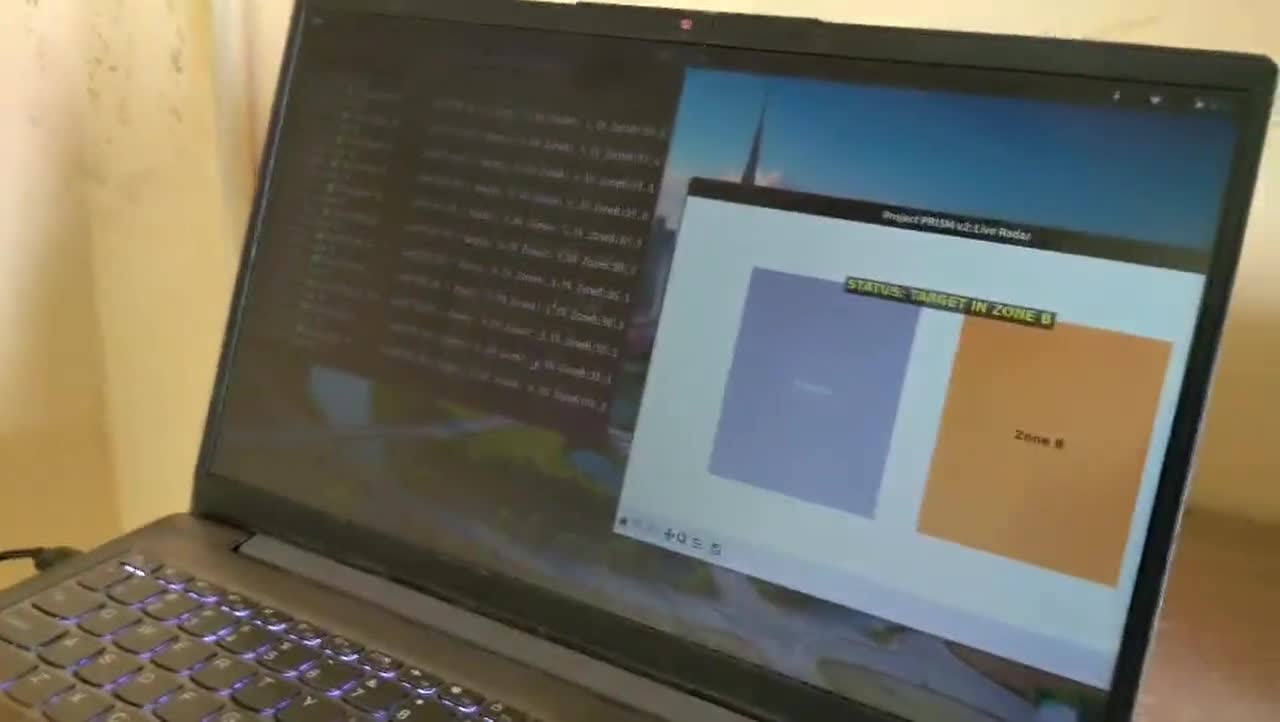 /zerotouch
ZeroTouch
Which zone of a room you are in, from the Wi-Fi signal of a $4 ESP32.
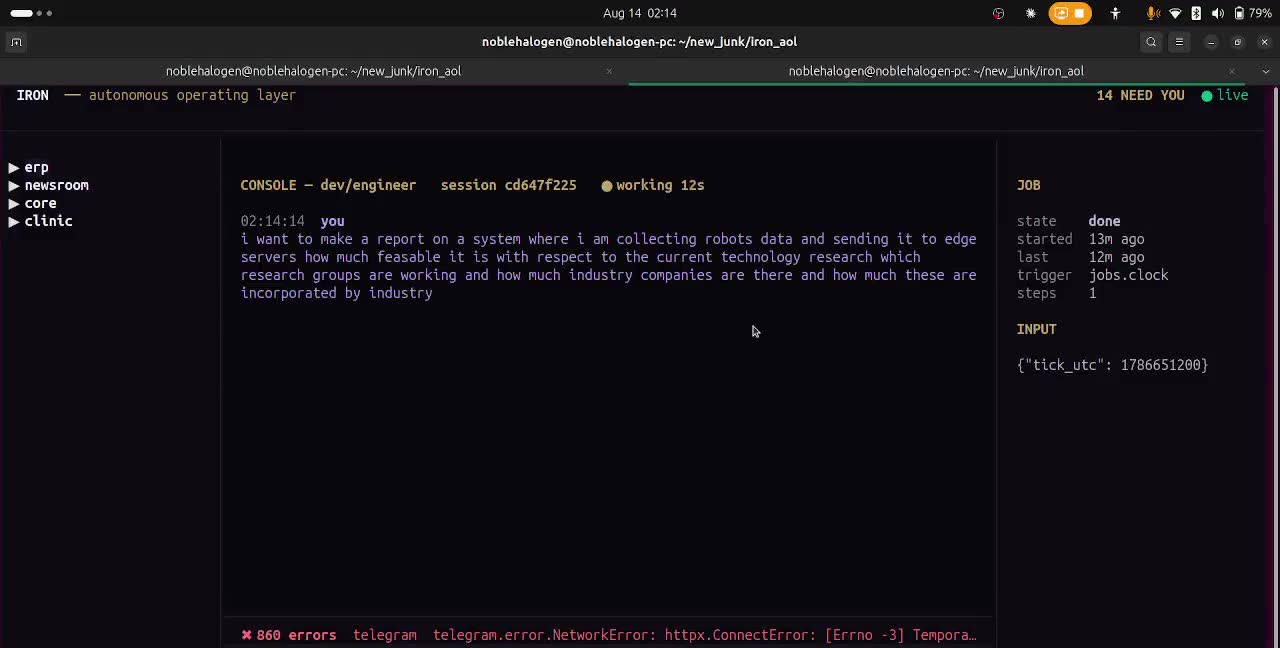 /iron-overview
Iron
Agents declared as markdown folders, run as supervised ROS 2 processes, recorded on a log nobody can edit.
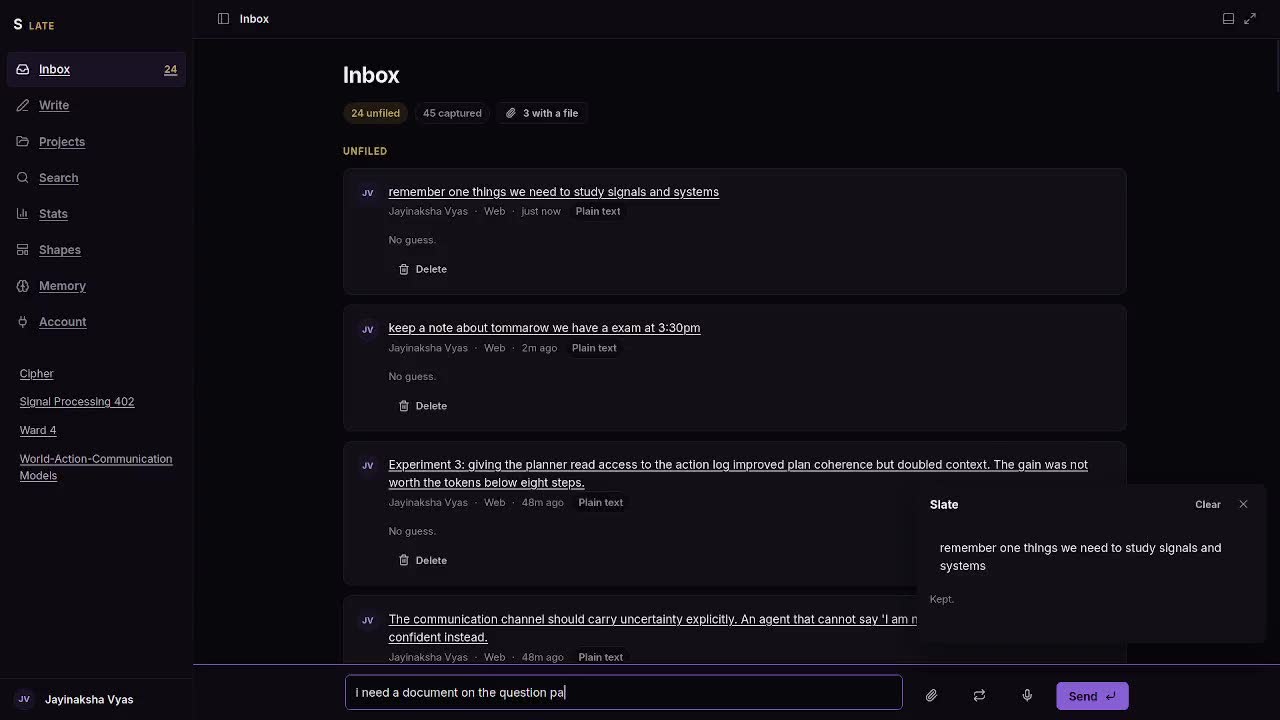 /slate
Slate
Send it anything. Ask for the document later — in your format, every block cited.
Newsroom
No editor — only a published ladder that decides what counts as verified, and posts its own corrections.
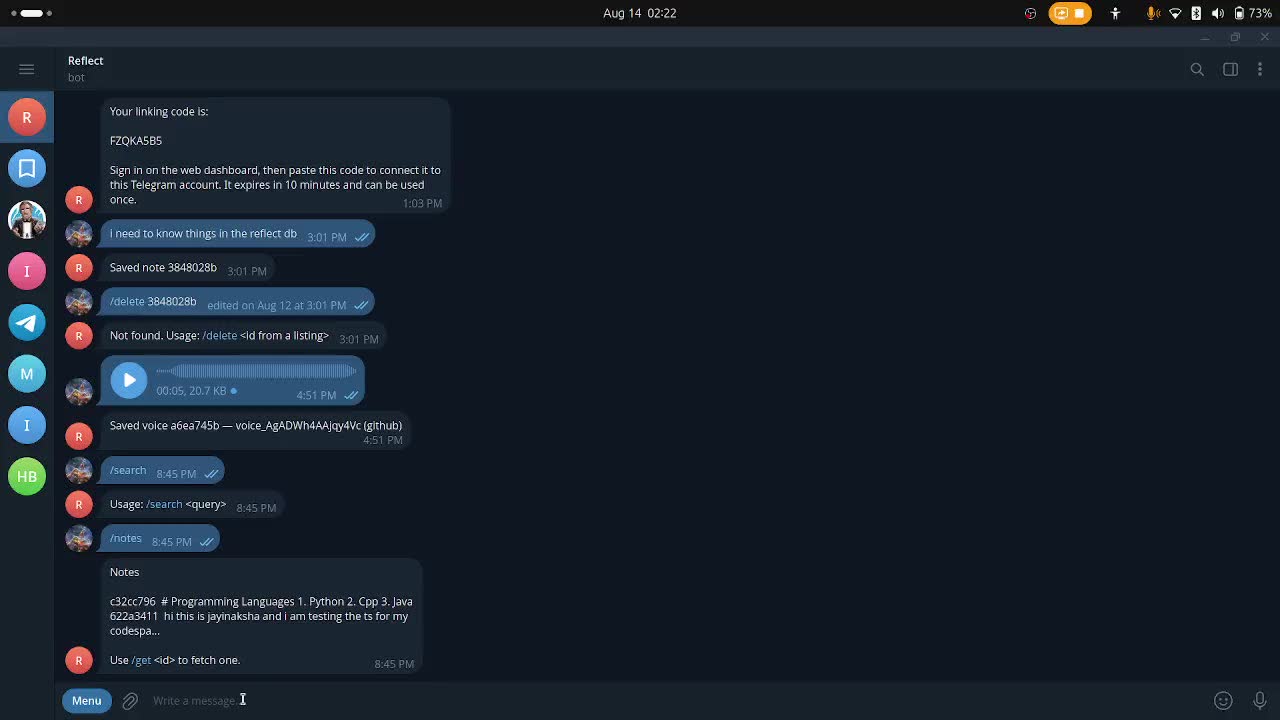 /telenotes
telenotes
Telegram in, markdown in your own git repo out. Bot, dashboard and terminal client.
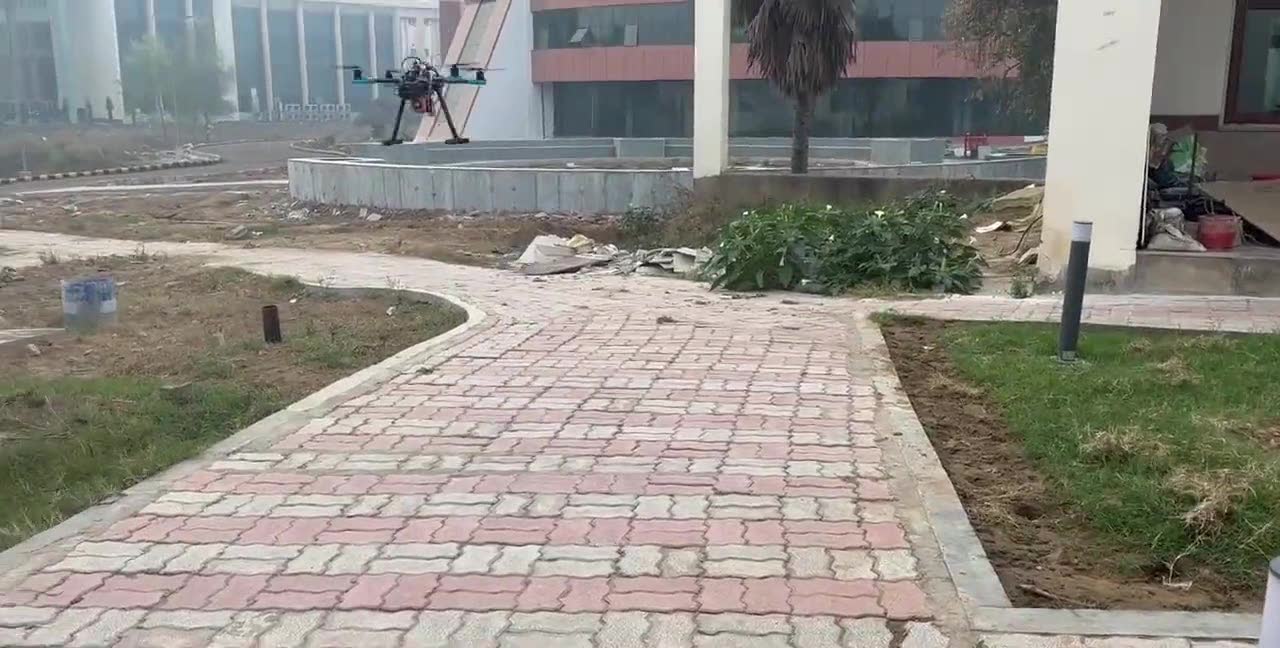 /portfolio/projects/…
Motor-failure recovery
A quadcopter loses a rotor mid-flight, holds attitude on three, and lands.